Selected work · January–August 2026
My work at Qualia
Building the infrastructure that connects vision-language-action models to robots in the real world.
- Engineering InternJanuary–June 2026
- Junior EngineerJune–August 2026
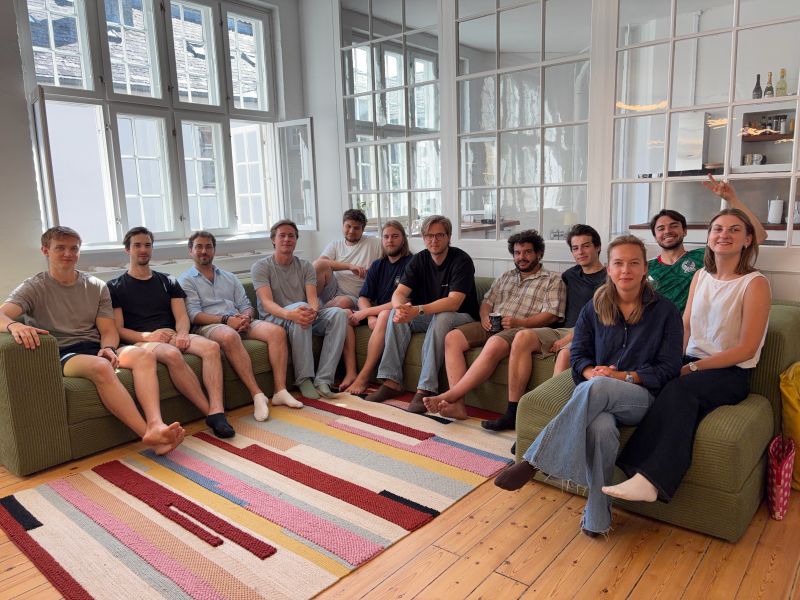
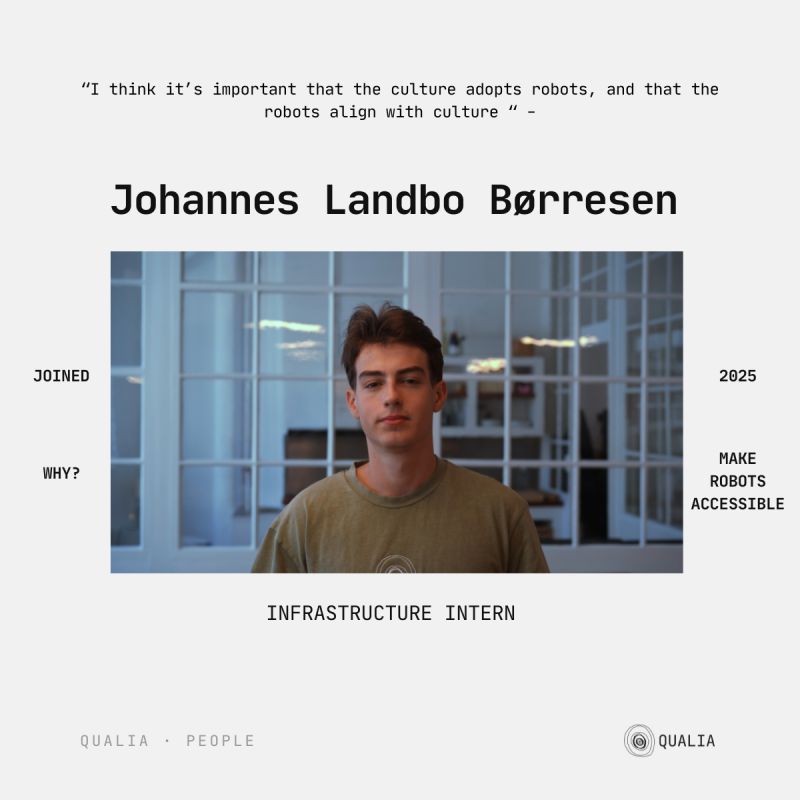
People at Qualia
My role
I joined Qualia as an engineering intern in January 2026 and continued as a junior engineer from June to August 2026. I worked on infrastructure for vision-language-action (VLA) models, teleoperation, and robotics.
VLA infrastructure
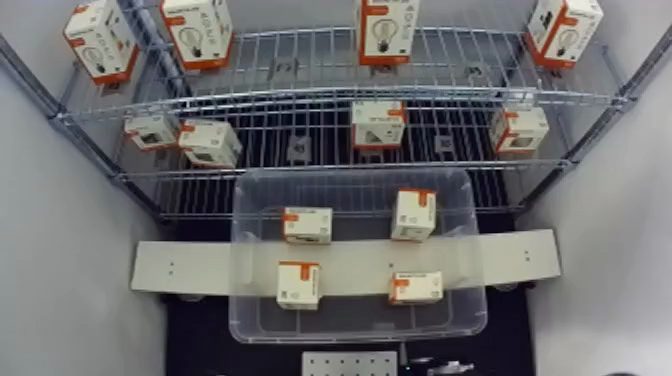
VLA models use camera observations and language instructions to predict robot actions. My work covered real-time inference, action chunking, and deployment systems: the software that connects model predictions to robot execution. Action chunking predicts a sequence of actions together rather than only the next movement.
Teleoperation
Teleoperation lets a person control a robot remotely. At Qualia, I worked on teleoperation alongside the model infrastructure and robotics systems.
From model predictions to robot actions
A model is one part of a robotics system. Camera observations and language instructions need to reach the model, and its predicted actions need to reach the robot in time to be useful.
My work focused on that connection: real-time inference, action chunking, and deployment. Action chunking means predicting a sequence of actions together, rather than only the next individual movement.
VLA · inference · Python · systems
Qualia on LinkedIn
More from LinkedIn
A look at Qualia
Robotics at Qualia